
Associate II
September 25, 2024
Question

MCSDK 6.3.0 + FreeRTOS Motor Pilot doen't connect (MCP: ASPEP BEACON TIMEOUT)

  • September 25, 2024
  • 5 replies
  • 3026 views

Hello everyone,

I have a motor control project that I'm testing out using Motor Pilot. If I generate it with FreeRTOS support, Motor Pilot can't connect to the board (the board sends a probably malformed ASPEP_RESP and then it's always a timeout).
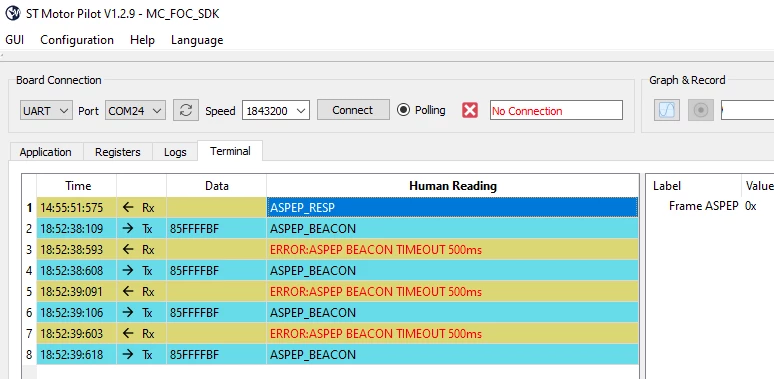
grisharevzin_0-1727248546108.png

I have verified that motor control code is working correctly with test code (the motor spins as expected):

void test_task(const void *arg)
{
vTaskDelay(5000);
(void)arg;
MC_AcknowledgeFaultMotor1();
MC_ProgramSpeedRampMotor1_F(250, 1000);
MC_StartMotor1();
vTaskSuspend(NULL);
}

Noticed that void ASPEP_HWReset(ASPEP_Handle_t *pHandle) from aspep.c is always getting called.

If I untick the FreeRTOS button in the workbench and regenerate the code (keeping all other settings), then MCP works as expected.

General params:

  • MCSDK 6.3.0
  • FOC
  • EVSPIN32G4 

Maybe this is known issue and there's a fix/workaround?

This topic has been closed for replies.

5 replies

ST Employee
September 25, 2024

Hello @grisharevzin ,

Could you try with the latest version of MCSDK (6.3.1) which has been released?

It should fix your issue.

BRs

If you agree with my answer, please accept it by clicking on 'Accept as solution'.
Associate II
September 25, 2024

Hi @LHOUE,

I've regenerated and recompiled everything with 6.3.1, same issue (void ASPEP_HWReset(ASPEP_Handle_t *pHandle) is always getting called if I'm trying to connect with Motor Pilot).


grisharevzin_0-1727275841410.png


Associate II
November 14, 2024

Did you find a resolution to this issue? I am having the same problem

Associate II
November 14, 2024

Nope, sorry. It's either FreeRTOS or MCP. My intuition tells me it should be easy enough to debug but I didn't go this way.