

How to use STM32F100 to measure a sinwave's frequency by input cature mode of TIM3 ?
How to use STM32F100 to measure a sinwave's frequency by input cature mode of TIM3 ?
I would like to measure sinewaves of three frequency, 39Khz�?40Khz and 41Khz.
Voltage level (0V-3V)
The 39khz period is 25.64us.
The 40khz period is 25us.
The 41khz period is 24.39us.
I use timer to count.
TIM_CLK= 24M 1s =24000000 clk
counting times = 1s/24000000 clk = 0.042 us/clk , prescaler =1
The timer count once per 0.042 second.
Calculation count value: (I should get the following values )
39kHz: 25.64us/0.042us = 610
40kHz: 25us /0.042us = 595
41kHz: 24.39us/0.042us = 580
Experimentalphoto:
1: at intput 39kHz sinewave
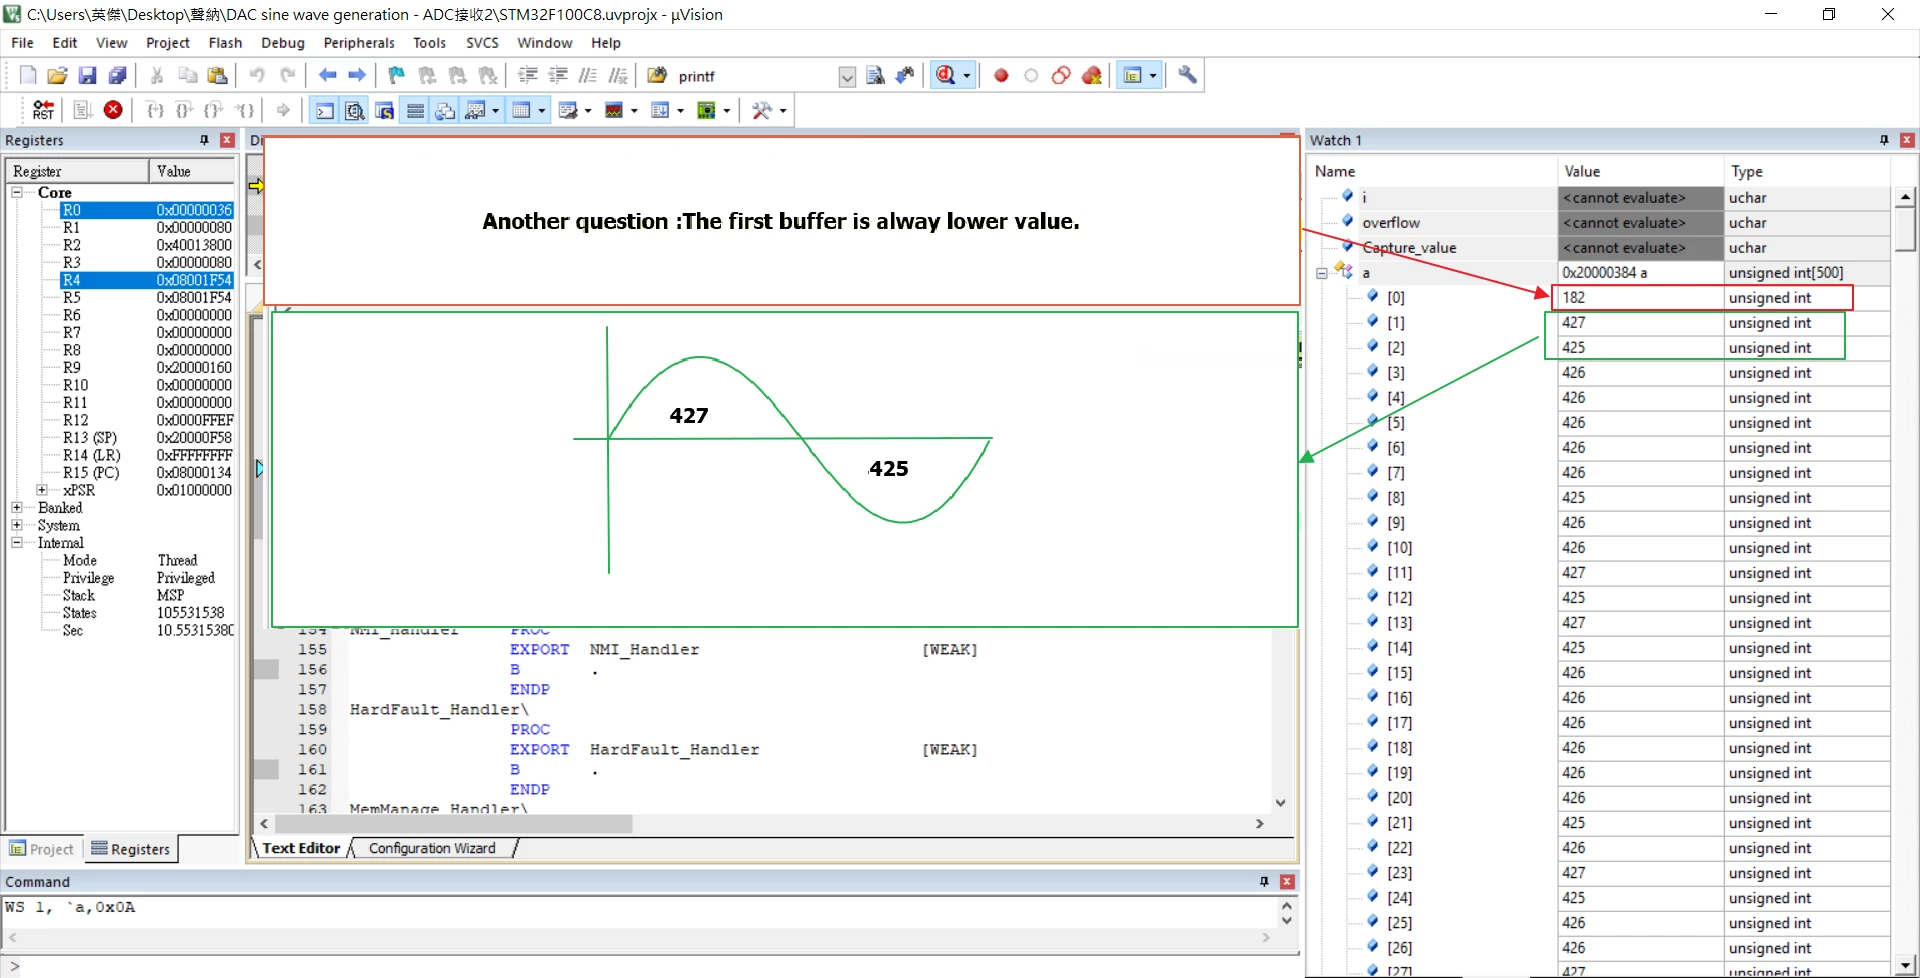
count value=427+425 =852 >> 610
f=1/T=1/(852*0.042us)=27.9Khz it is wrong.
2:at intput 40KHz sinewave

count value =411+410=821>> 595
f=1/T=1/(821*0.042us)=29Khz it is wrong.
3:at intput 41K sinewave
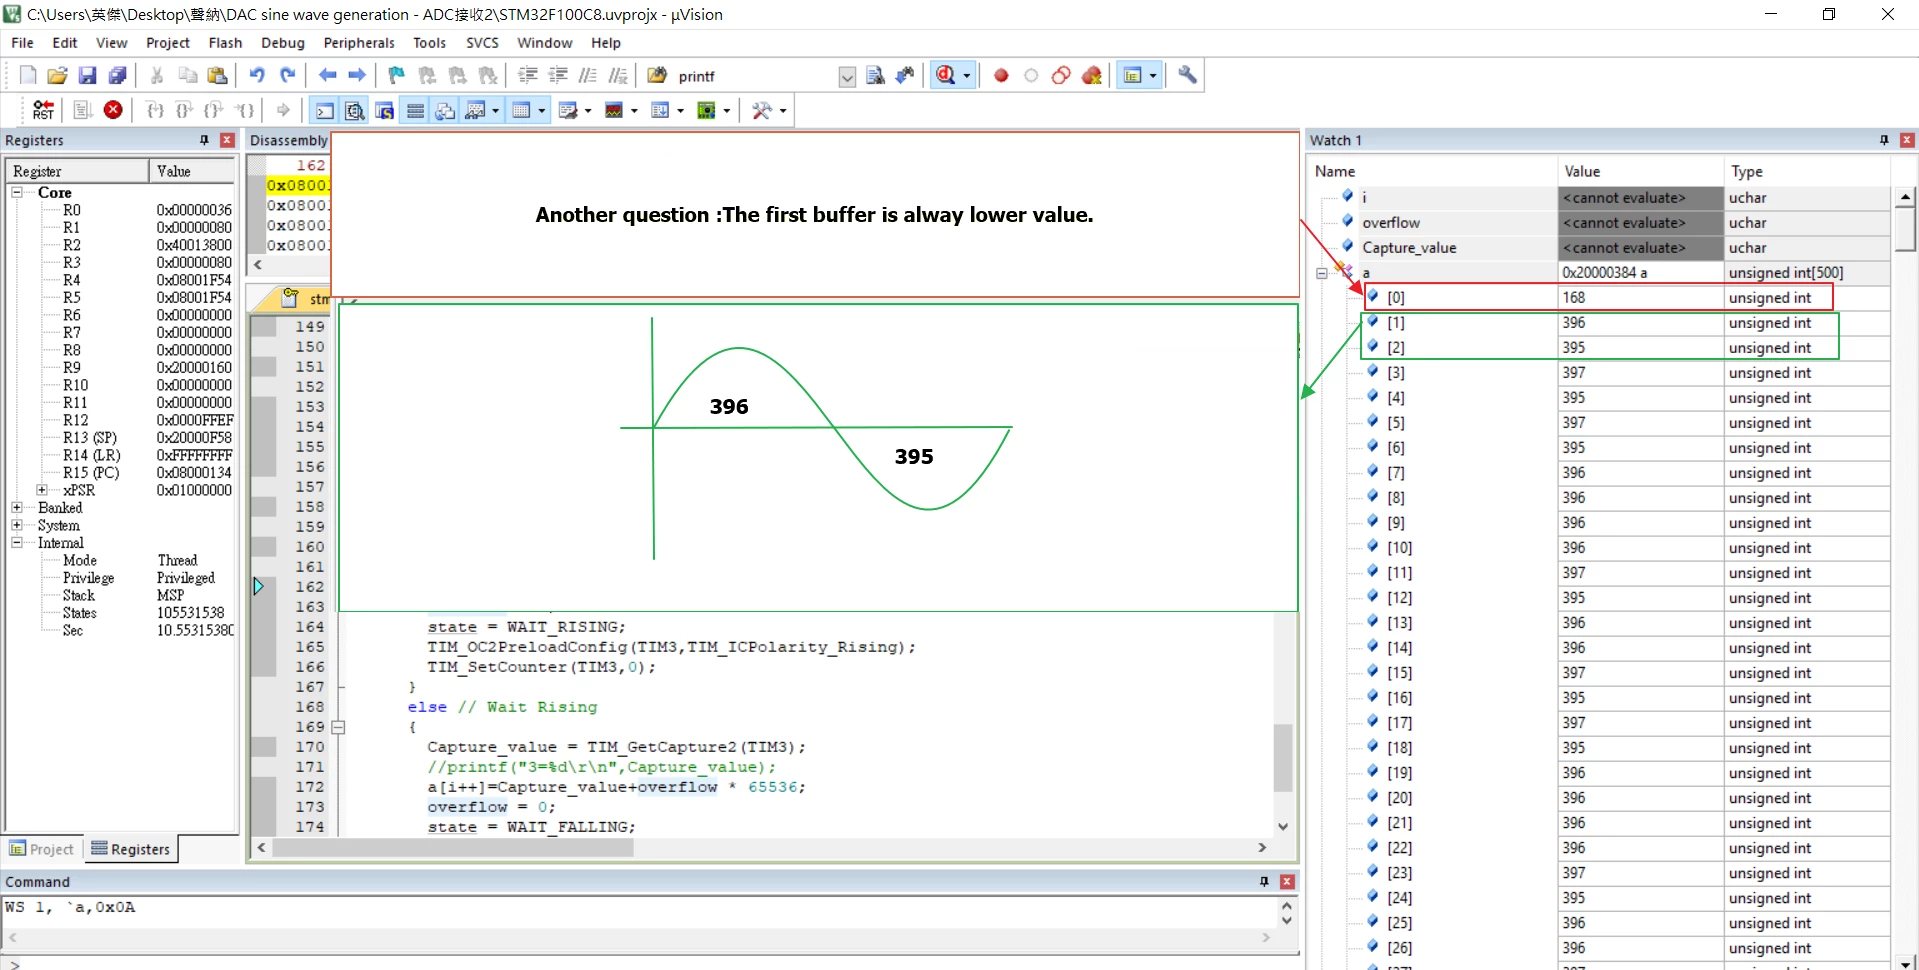
count value =396+395=791>> 580
f=1/T=1/(791*0.042us)=30.1Khz it is wrong.
I study the datasheet and try it ,however I still can't get to correct frequency.
code:
void Rcc_init(void)
{
RCC_DeInit();
RCC_HSICmd(ENABLE);
RCC_PLLConfig(RCC_PLLSource_HSI_Div2,RCC_PLLMul_6);
RCC_PLLCmd(ENABLE);
while(RCC_GetFlagStatus(RCC_FLAG_PLLRDY)==RESET){}
RCC_HCLKConfig(RCC_SYSCLK_Div1);//24M
RCC_PCLK1Config(RCC_HCLK_Div1); //24M
RCC_PCLK2Config(RCC_HCLK_Div1); //24M
FLASH_PrefetchBufferCmd(FLASH_PrefetchBuffer_Enable);
FLASH_SetLatency(FLASH_Latency_2);
RCC_SYSCLKConfig(RCC_SYSCLKSource_PLLCLK);
while(RCC_GetSYSCLKSource()!=0x08){}
}
void init(void)
{
Rcc_init();
TIM3_Cap_Init(0xFFFF,0);
}
int main(void)
{
init();
while(1)
{}
}
void TIM3_Cap_Init(uint16_t arr,uint16_t psc)
{
NVIC_InitTypeDef NVIC_InitStruct;
TIM_TimeBaseInitTypeDef TIM_TimeBaseInitStruct;
TIM_ICInitTypeDef TIM_ICInitStruct;
GPIO_InitTypeDef GPIO_InitStruct;
RCC_APB1PeriphClockCmd(RCC_APB1Periph_TIM3, ENABLE);
RCC_APB2PeriphClockCmd(RCC_APB2Periph_GPIOA | RCC_APB2Periph_AFIO, ENABLE);
//--------------------PIN----------------------------//
//PA7 TIM3_CH2 en.CD00246267 P.108
GPIO_InitStruct.GPIO_Mode = GPIO_Mode_IN_FLOATING;
GPIO_InitStruct.GPIO_Speed = GPIO_Speed_50MHz;
GPIO_InitStruct.GPIO_Pin = GPIO_Pin_7;
GPIO_Init(GPIOA, &GPIO_InitStruct);
TIM_Cmd(TIM3,DISABLE);
TIM_DeInit(TIM3);
TIM_TimeBaseStructInit(&TIM_TimeBaseInitStruct);
TIM_TimeBaseInitStruct.TIM_ClockDivision = TIM_CKD_DIV1; //tDTS = tCK_INT
TIM_TimeBaseInitStruct.TIM_CounterMode = TIM_CounterMode_Up;
TIM_TimeBaseInitStruct.TIM_Period = arr;
TIM_TimeBaseInitStruct.TIM_Prescaler = psc;
TIM_TimeBaseInit(TIM3, &TIM_TimeBaseInitStruct);
TIM_ICInitStruct.TIM_Channel = TIM_Channel_2;
TIM_ICInitStruct.TIM_ICFilter = 0; //IC1F
TIM_ICInitStruct.TIM_ICPolarity = TIM_ICPolarity_Rising;
TIM_ICInitStruct.TIM_ICPrescaler = TIM_ICPSC_DIV1;
TIM_ICInitStruct.TIM_ICSelection = TIM_ICSelection_DirectTI;
TIM_ICInit(TIM3,&TIM_ICInitStruct);
TIM_ClearFlag(TIM3,TIM_FLAG_Update);
TIM_ClearITPendingBit(TIM3,TIM_IT_Update | TIM_IT_CC2);
TIM_ITConfig(TIM3,TIM_IT_Update | TIM_IT_CC2,ENABLE);
NVIC_PriorityGroupConfig(NVIC_PriorityGroup_2);
NVIC_InitStruct.NVIC_IRQChannel = TIM3_IRQn;
NVIC_InitStruct.NVIC_IRQChannelCmd = ENABLE;
NVIC_InitStruct.NVIC_IRQChannelPreemptionPriority = 0;
NVIC_InitStruct.NVIC_IRQChannelSubPriority = 0;
NVIC_Init(&NVIC_InitStruct);
TIM_Cmd(TIM3,ENABLE);
}
#define START 0x01
#define WAIT_RISING 0x02
#define WAIT_FALLING 0x03
uint32_t a[500]={0};
void TIM3_IRQHandler(void)
{
static uint32_t overflow=0;
static uint32_t state=START;
uint32_t Capture_value=0;
static uint16_t i=0;
if(i<500)
{
if(TIM_GetITStatus(TIM3,TIM_IT_Update)!=RESET)
{
overflow++;
}
else if (TIM_GetITStatus(TIM3,TIM_IT_CC2)!=RESET)
{
if(state ==START)
{
overflow=0;
TIM_SetCounter(TIM3,0);
state = WAIT_FALLING;
TIM_OC2PolarityConfig(TIM3,TIM_ICPolarity_Falling);
}
else if(state == WAIT_FALLING)
{
Capture_value = TIM_GetCapture2(TIM3);
//printf("1=%d\r\n",Capture_value);
a[i++]=Capture_value+overflow * 65536;
overflow = 0;
state = WAIT_RISING;
TIM_OC2PreloadConfig(TIM3,TIM_ICPolarity_Rising);
TIM_SetCounter(TIM3,0);
}
else // Wait Rising
{
Capture_value = TIM_GetCapture2(TIM3);
//printf("3=%d\r\n",Capture_value);
a[i++]=Capture_value+overflow * 65536;
overflow = 0;
state = WAIT_FALLING;
TIM_OC2PreloadConfig(TIM3,TIM_ICPolarity_Falling);
TIM_SetCounter(TIM3,0);
}
}
else{};
}
TIM_ClearITPendingBit(TIM3,TIM_IT_Update | TIM_IT_CC2);
}
