
Konami
Senior
May 12, 2023
Solved

CAN-FD stops mid-frame for higher data rates

  • May 12, 2023
  • 2 replies
  • 1180 views

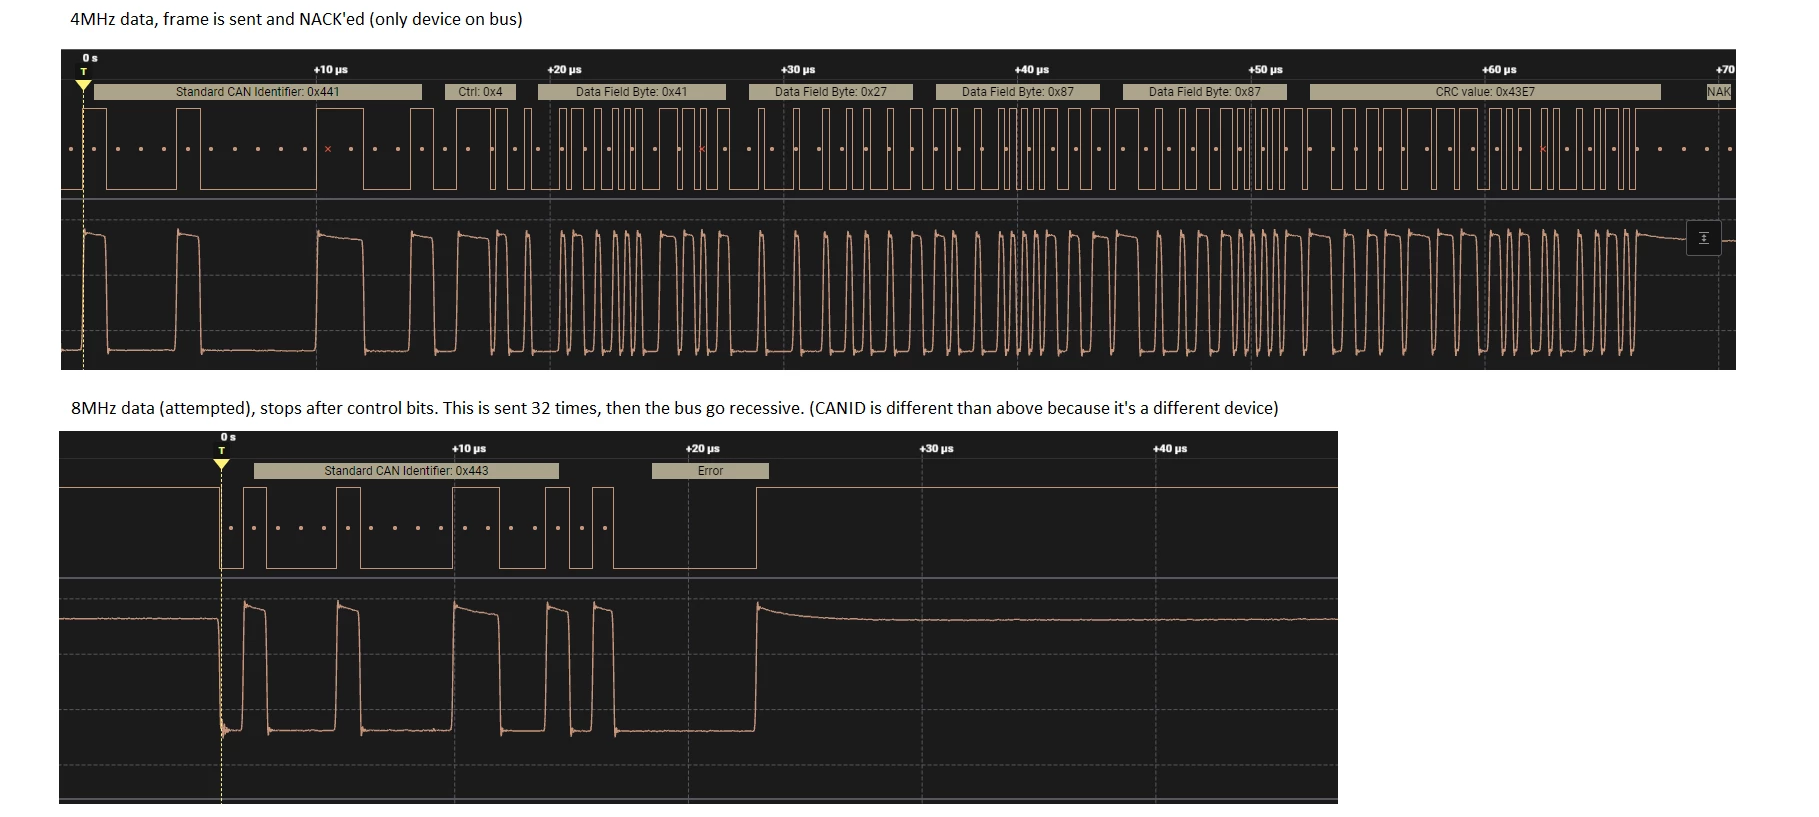
I'm trying to setup a CAN-FD example with data rate switching (1MHz nom, 8MHz data) on an STM32G0B1. It seems to work up to 4MHz, but when I decrease my divisor to get to 8MHz, the CAN frames just stop after the arbitration.

Here's my init code that works for 4MHz data. If I change hfdcan1.Init.DataPrescaler to = 1, things break.

 hfdcan1.Instance = FDCAN1;
 hfdcan1.Init.ClockDivider = FDCAN_CLOCK_DIV1;
 hfdcan1.Init.FrameFormat = FDCAN_FRAME_FD_BRS;
 hfdcan1.Init.Mode = FDCAN_MODE_NORMAL;
 hfdcan1.Init.AutoRetransmission = DISABLE;
 hfdcan1.Init.TransmitPause = ENABLE;
 hfdcan1.Init.ProtocolException = DISABLE;
 hfdcan1.Init.NominalPrescaler = nom_divisor;
 hfdcan1.Init.NominalSyncJumpWidth = 1;
 hfdcan1.Init.NominalTimeSeg1 = 13;
 hfdcan1.Init.NominalTimeSeg2 = 2;
 hfdcan1.Init.DataPrescaler = 2;//data_divisor;
 hfdcan1.Init.DataSyncJumpWidth = 1;
 hfdcan1.Init.DataTimeSeg1 = 6;
 hfdcan1.Init.DataTimeSeg2 = 1;
 hfdcan1.Init.StdFiltersNbr = 1;
 hfdcan1.Init.ExtFiltersNbr = 1;
 hfdcan1.Init.TxFifoQueueMode = FDCAN_TX_FIFO_OPERATION;
 if (HAL_FDCAN_Init(&hfdcan1) != HAL_OK)
 {
 Error_Handler();
 }

Here's what it looks like when it breaks

_legacyfs_online_stmicro_images_0693W00000bjzdlQAA.png 

The bus has 2x TI transceiver, terminated on both ends. Any idea why the data stops sending when the data rate switch should occur or any suggestions on how to debug this?

This topic has been closed for replies.
Best answer by Konami

I believe this was due to missing the below from the output of CubeMX. See the STM32G0Cxx FDCAN examples for more details.

 /* Configure and enable Tx Delay Compensation, required for BRS mode.
 TdcOffset default recommended value: DataTimeSeg1 * DataPrescaler
 TdcFilter default recommended value: 0 */
 if (HAL_FDCAN_ConfigTxDelayCompensation(&hfdcan1, CAN_DELAYCOMP, 0) != HAL_OK)
 {
 Error_Handler();
 }
 
 if (HAL_FDCAN_EnableTxDelayCompensation(&hfdcan1) != HAL_OK)
 {
 Error_Handler();
 }

2 replies

Konami
KonamiAuthor
Senior
May 13, 2023

I should add, that I'm kind of suspecting the timing settings as the culprit, because when I use the recommended timing numbers from Kvaser, I see the same behavior even at 4MHz. I don't believe I'm violating the limits of these values but perhaps I'm missing something else

Konami
KonamiAuthorBest answer
Senior
May 22, 2023

I believe this was due to missing the below from the output of CubeMX. See the STM32G0Cxx FDCAN examples for more details.

 /* Configure and enable Tx Delay Compensation, required for BRS mode.
 TdcOffset default recommended value: DataTimeSeg1 * DataPrescaler
 TdcFilter default recommended value: 0 */
 if (HAL_FDCAN_ConfigTxDelayCompensation(&hfdcan1, CAN_DELAYCOMP, 0) != HAL_OK)
 {
 Error_Handler();
 }
 
 if (HAL_FDCAN_EnableTxDelayCompensation(&hfdcan1) != HAL_OK)
 {
 Error_Handler();
 }