PCong.1
Associate III
Feb 16, 2022 1:23 PM UTC
Solved

how to store signed hexadecimal data from a sensor and identify if the hex is negative or positive?

I have a sensor that can communicate via UART, I send a command and the sensor answers me with a hexadecimal frame.

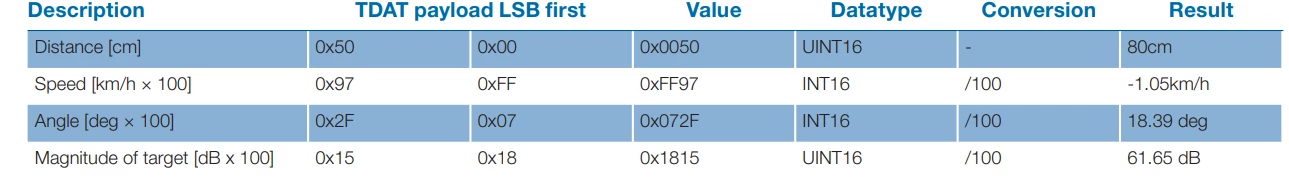
I can have distance, angle, velocity values.

0693W00000JQ2dNQAT.png0693W00000JQ2dIQAT.png0693W00000JQ2dXQAT.png 

I know how to store the frame in a buffer but I don't know how to store it in hexa to keep the form 0xFF6F and identify if the value is negative or positive.

There is the code i have made to identifier and read value inside the buffer

extern uint8_t flag;
extern UART_HandleTypeDef huart1;
 
//Initialisation des commandes capteur.
uint8_t INIT[12] = {0x49, 0x4E, 0x49, 0x54, 0x04, 0x00, 0x00, 0x00, 0x00, 0x00, 0x00, 0x00}; // Init commande for the first communication and fix the Bauderate
uint8_t TDAT[12] = {0x47, 0x4E, 0x46, 0x44, 0x04, 0x00, 0x00, 0x00, 0x08, 0x00, 0x00, 0x00}; // TDAT to detect target and get the rang and the angle
uint8_t GBYE[8] = {0x49, 0x4E, 0x49, 0x54, 0x00, 0x00, 0x00, 0x00}; // commande to disconnect the sensor
 
void sensor_init(void){
	HAL_UART_Transmit(&huart1, INIT, sizeof(INIT), 13);
	HAL_Delay(75);
}
 
void sensor_data(void){
	if (flag == 1) {
		HAL_UART_Transmit(&huart1, TDAT, sizeof(TDAT), 13);
		HAL_Delay(100);
		flag = 0;
	}
	distance = k_ld7_resp[8] + k_ld7_resp[9]*0x100;
	angle = (k_ld7_resp[12] + k_ld7_resp[13]*0x100) / 100;

The code for the uart callback

/*K_LD7 private variable*/
uint8_t flag = 0;
uint8_t rxByte;
 
char k_ld7_resp[RxBuff_SIZE];
char MainBuf_K_LD7[Main_buf_SIZE];


void Ringbuf_Reset(void){
	memset(MainBuf_K_LD7, '\0', Main_buf_SIZE);
	memset(k_ld7_resp, '\0', RxBuff_SIZE);
}
 
void HAL_UARTEx_RxEventCallback(UART_HandleTypeDef *huart, uint16_t Size){
	if (huart->Instance == USART1) {
		memcpy(MainBuf_K_LD7, k_ld7_resp, Size);
		flag = 1;
		HAL_UARTEx_ReceiveToIdle_DMA(huart, k_ld7_resp, RxBuff_SIZE);
		 __HAL_DMA_DISABLE_IT(&hdma_usart1_rx, DMA_IT_HT);
	}
}
This topic has been closed for replies.
MM..1
MM..1Best answer
Super User
Feb 16, 2022 2:43 PM UTC

you say something about hex but you send and rec over UART binary data.

In payload table you have info for types and conversions

simply use

int16_t angle; //stored *100 value dont use float if not required
uint16_t distance;
 
angle = *((int16_t *)&k_ld7_resp[12]);
distance = *((uint16_t *)&k_ld7_resp[8]);

6 replies

MM..1
MM..1Best answer
Super User
Feb 16, 2022 2:43 PM UTC

you say something about hex but you send and rec over UART binary data.

In payload table you have info for types and conversions

simply use

int16_t angle; //stored *100 value dont use float if not required
uint16_t distance;
 
angle = *((int16_t *)&k_ld7_resp[12]);
distance = *((uint16_t *)&k_ld7_resp[8]);

PCong.1
PCong.1Author
Associate III
Feb 16, 2022 2:59 PM UTC

I tried with type int16 for the angle, now I have the negative sign but the value is completely wrong.

void sensor_data(void){
	if (flag == 1) {
		HAL_UART_Transmit(&huart1, TDAT, sizeof(TDAT), 13);
		HAL_Delay(100);
		flag = 0;
	}
	distance = k_ld7_resp[8] + k_ld7_resp[9]*0x100;
	angle = (*(int16_t*)&k_ld7_resp[12] + (*(int16_t*)&k_ld7_resp[13])*0x100) / 100;

0693W00000JQ3wVQAT.png

MM..1
Super User
Feb 16, 2022 3:09 PM UTC

Your conversion is bad dont need handle [13]*256 use my syntax and if you need angle in debree add /100. You dont show how type is angle global in your code.

Nikita91
Lead II
Feb 16, 2022 2:53 PM UTC

Do not use payload bytes individually. Define a struct to receive the paylod:

typedef struct
{
 uint32_t header ;
 uint32_t length ;
 uint16_t distance ;
 int16_t speed ;
 int16_t angle ;
 uint16_t mag ;
} msg_t ;
 
msg_t data ;
 

If you use the data buffer to receive the sensor message, you can directly access each values.

If you have many messages types, define a struct for each message.