here my test, it works on my side with trace using TeraTerm.
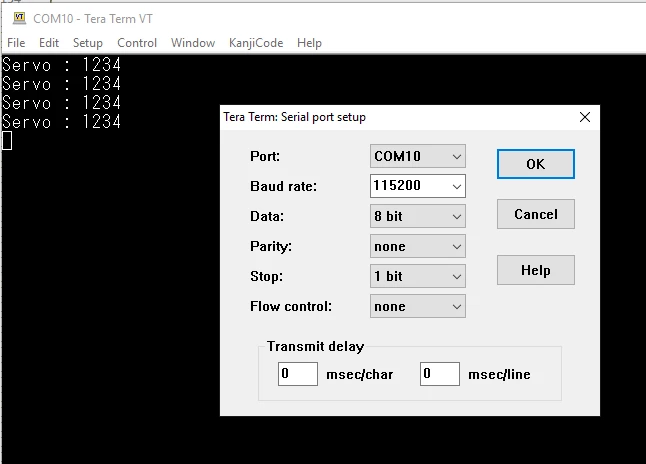
main.c
/* USER CODE BEGIN Includes */
#include <stdio.h>

/* USER CODE END Includes */
/* USER CODE BEGIN PV */
char str[16] = {0};
uint32_t servopot = 1234;

/* USER CODE END PV */
int main(void)
{
 /* USER CODE BEGIN 1 */

 /* USER CODE END 1 */

 /* MCU Configuration--------------------------------------------------------*/

 /* Reset of all peripherals, Initializes the Flash interface and the Systick. */
 HAL_Init();

 /* USER CODE BEGIN Init */

 /* USER CODE END Init */

 /* Configure the system clock */
 SystemClock_Config();

 /* USER CODE BEGIN SysInit */

 /* USER CODE END SysInit */

 /* Initialize all configured peripherals */
 MX_GPIO_Init();
 MX_USART2_UART_Init();
 /* USER CODE BEGIN 2 */

 int size_len = sprintf (str, "Servo : %lu\n", servopot);

 /* USER CODE END 2 */

 /* Infinite loop */
 /* USER CODE BEGIN WHILE */
 while (1)
 {
 	HAL_UART_Transmit (&huart2, (uint8_t *)str, size_len, HAL_MAX_DELAY);
 	HAL_Delay(1000);
 /* USER CODE END WHILE */

 /* USER CODE BEGIN 3 */
 }
 /* USER CODE END 3 */
}
Can you shareyour code (UART2 setup) and hardware you use ?


