Solved
HAL_TIM_ReadCapturedValue returning zero even if interrupt is called
Hi!
I have enabled encoder and input capture and only encoder works.
The reason is that CCR3 and CCR4 is zero.
HAL_TIM_ReadCapturedValueWhy does this happen? I have enabled NVIC for TIM4 and TIM19 and HAL_TIM_IC_CaptureCallback is called when the Input Capture get a rising edge, but still, CCR3 and CCR4 is zero. Why?
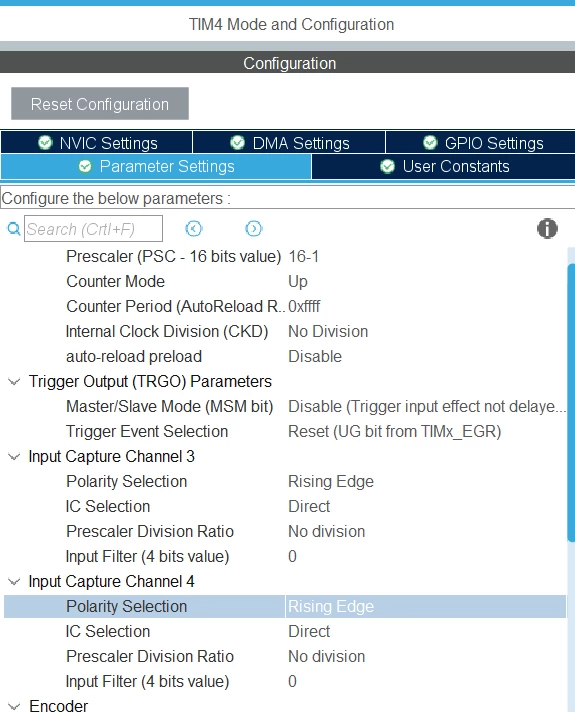
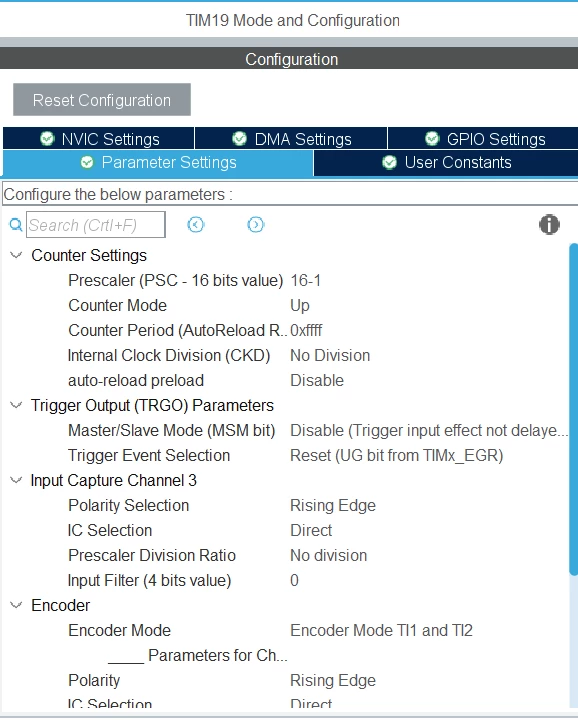
Here is when I am in the debug mode.
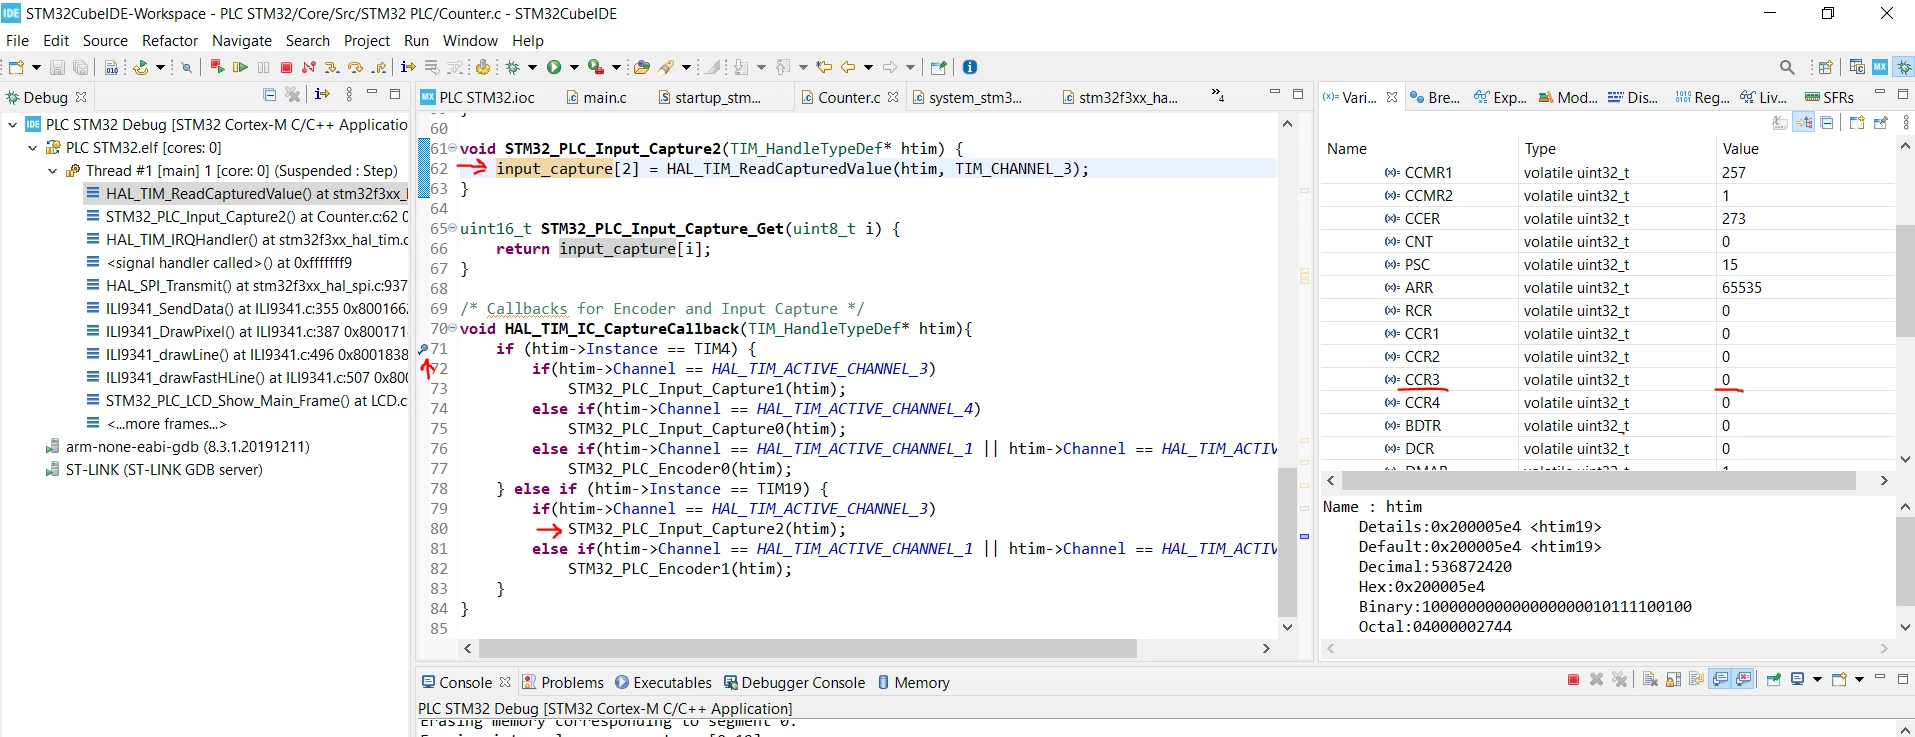 Here is my complete and very simple C-code.
/*
 * Counter.c
 *
 * Created on: Jun 13, 2021
 * Author:
 */

#include "Functions.h"

static uint16_t encoder[2];
volatile static uint16_t input_capture[3];

void STM32_PLC_Start_Counters(TIM_HandleTypeDef* htim4, TIM_HandleTypeDef* htim19) {
	/* Encoder */
	HAL_TIM_Encoder_Start_IT(htim4, TIM_CHANNEL_ALL);
	HAL_TIM_Encoder_Start_IT(htim19, TIM_CHANNEL_ALL);
	encoder[0] = 0x8000; /* Initial settings */
	encoder[1] = 0x8000;

	/* Input Capture */
	HAL_TIM_IC_Start_IT(htim4, TIM_CHANNEL_3);
	HAL_TIM_IC_Start_IT(htim4, TIM_CHANNEL_4);
	HAL_TIM_IC_Start_IT(htim19, TIM_CHANNEL_3);
	input_capture[0] = 0; /* Initial settings */
	input_capture[1] = 0;
	input_capture[2] = 0;
}

void STM32_PLC_Encoder0(TIM_HandleTypeDef* htim) {
	bool encoder0_direction = !(__HAL_TIM_IS_TIM_COUNTING_DOWN(htim));

	/* Values between 0 and 0xFFFF */
	if(encoder0_direction)
		encoder[0] = 0x8000 + __HAL_TIM_GetCounter(htim); /* Positive rotation: 0x8000 - 0xFFFF */
	else
		encoder[0] = __HAL_TIM_GetCounter(htim) - 0x8000; /* Negative rotation: 0 - 0x7FFF */
}

void STM32_PLC_Encoder1(TIM_HandleTypeDef* htim) {
	bool encoder1_direction = !(__HAL_TIM_IS_TIM_COUNTING_DOWN(htim));

	/* Values between 0 and 0xFFFF */
	if(encoder1_direction)
		encoder[1] = 0x8000 + __HAL_TIM_GetCounter(htim); /* Positive rotation: 0x8000 - 0xFFFF */
	else
		encoder[1] = __HAL_TIM_GetCounter(htim) - 0x8000; /* Negative rotation: 0 - 0x7FFF */
}

uint16_t STM32_PLC_Encoder_Get(uint8_t i) {
	return encoder[i];
}

void STM32_PLC_Input_Capture0(TIM_HandleTypeDef* htim) {
	input_capture[0] = HAL_TIM_ReadCapturedValue(htim, TIM_CHANNEL_4);
}

void STM32_PLC_Input_Capture1(TIM_HandleTypeDef* htim) {
	input_capture[1] = HAL_TIM_ReadCapturedValue(htim, TIM_CHANNEL_3);
}

void STM32_PLC_Input_Capture2(TIM_HandleTypeDef* htim) {
	input_capture[2] = HAL_TIM_ReadCapturedValue(htim, TIM_CHANNEL_3);
}

uint16_t STM32_PLC_Input_Capture_Get(uint8_t i) {
	return input_capture[i];
}

/* Callbacks for Encoder and Input Capture */
void HAL_TIM_IC_CaptureCallback(TIM_HandleTypeDef* htim){
	if (htim->Instance == TIM4) {
		if(htim->Channel == HAL_TIM_ACTIVE_CHANNEL_3)
			STM32_PLC_Input_Capture1(htim);
		else if(htim->Channel == HAL_TIM_ACTIVE_CHANNEL_4)
			STM32_PLC_Input_Capture0(htim);
		else if(htim->Channel == HAL_TIM_ACTIVE_CHANNEL_1 || htim->Channel == HAL_TIM_ACTIVE_CHANNEL_2)
			STM32_PLC_Encoder0(htim);
	} else if (htim->Instance == TIM19) {
		if(htim->Channel == HAL_TIM_ACTIVE_CHANNEL_3)
			STM32_PLC_Input_Capture2(htim);
		else if(htim->Channel == HAL_TIM_ACTIVE_CHANNEL_1 || htim->Channel == HAL_TIM_ACTIVE_CHANNEL_2)
			STM32_PLC_Encoder1(htim);
	}
}