

Torque control issues with Nucleo F446 and X-Nucleo IHM07M1
Hello All,
I am using the Motor Control SDK and Workbench with the Nucleo F446 evaluation board and X-Nucleo IHM07M1 motor driver board, together with a PMSM 8 pole servo motor.
The issue I have is that when I set the torque ref (Iq) to > 0 and flux ref (Id) to 0 in the advanced tab of the workbench and press "start motor" the rotor fixates in the same way as in the alignment phase. When I turn the rotor shaft by hand it "snaps" into position at regular angle intervals.
To check for encoder and current measurement problems, I inserted some debugging code into the FOC algorithm to dump encoder position, Iq and Id values. This is a result from the debugging, where you can the rotor fixating and Iq and Id settling on their commanded values.
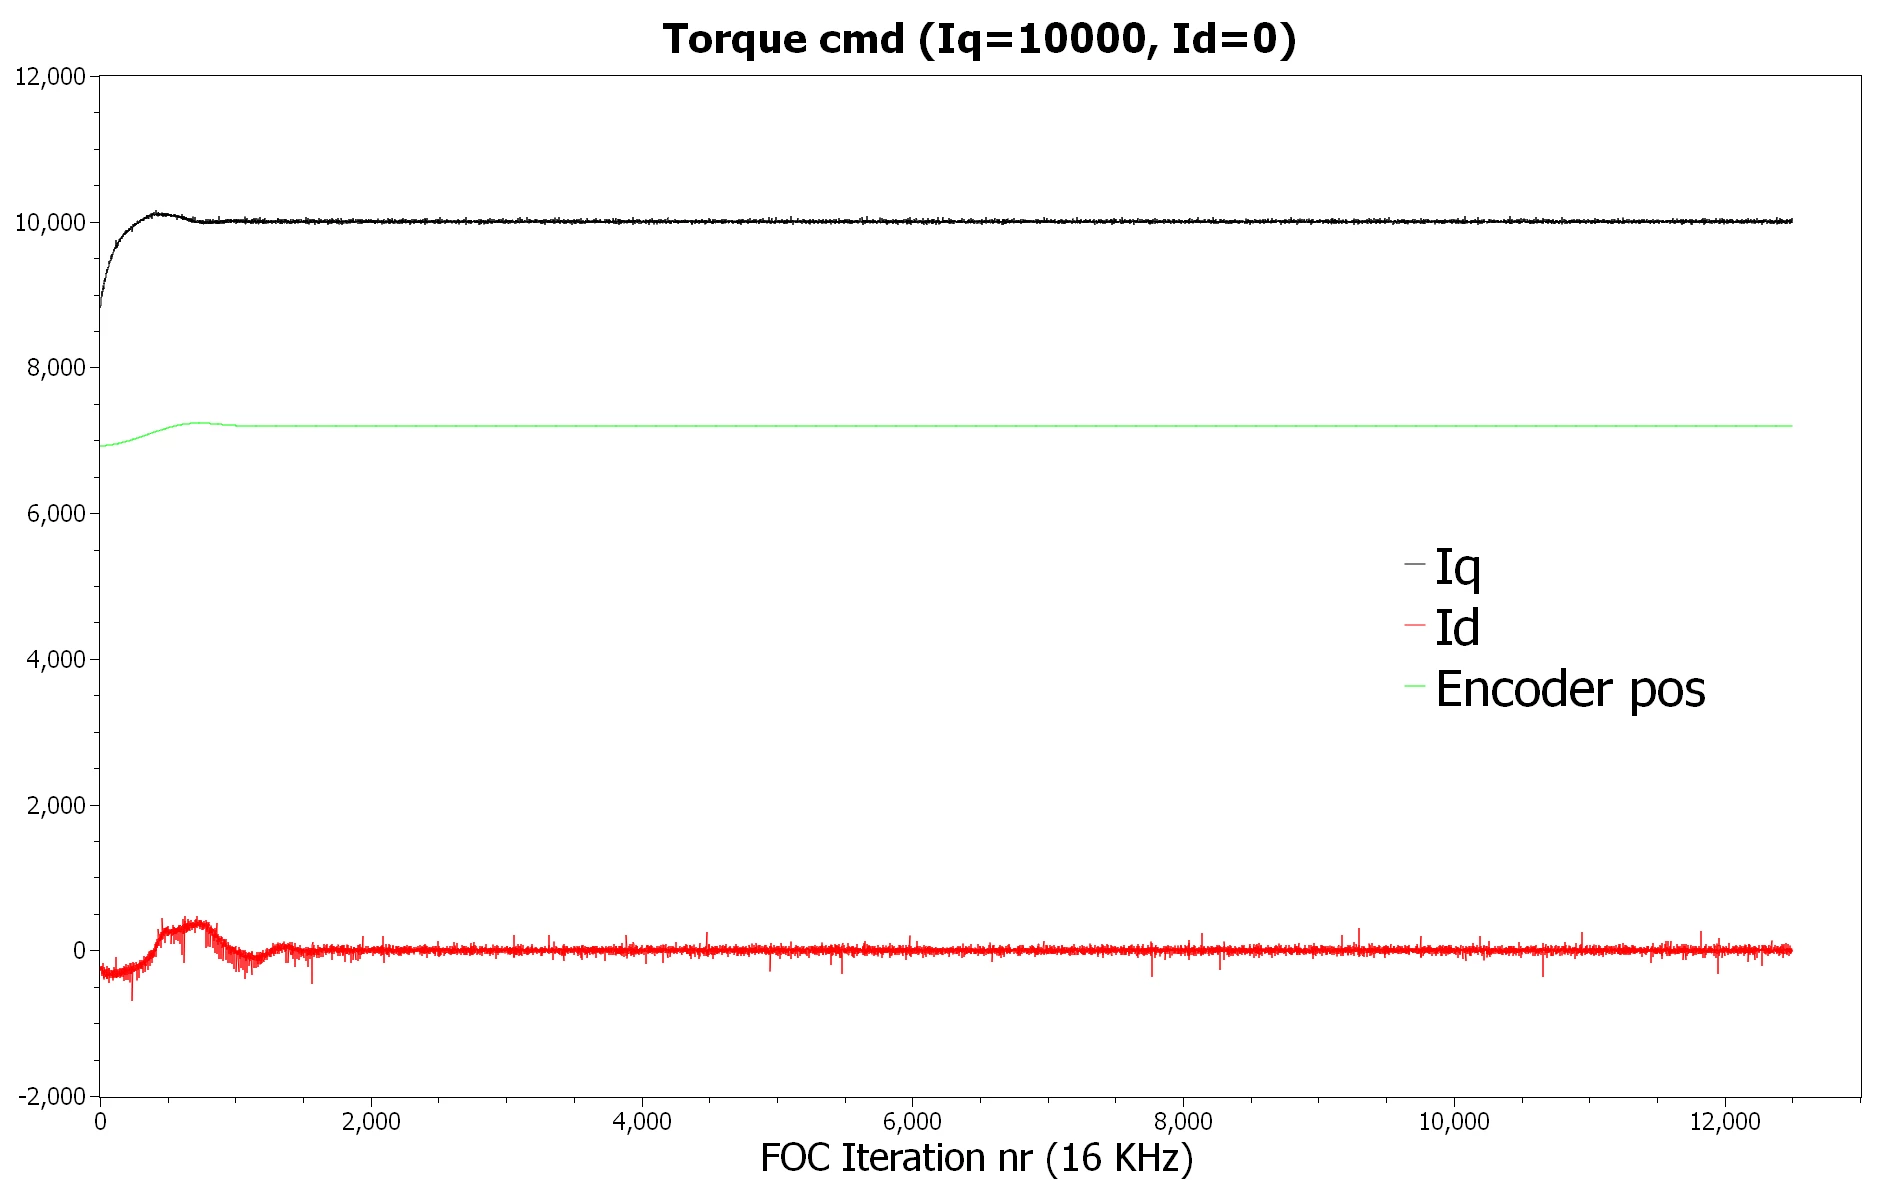
The thing is that I do not understand how the torque vector can settle on 10000 without the rotor starting to spin, and it should definitely not snap into position. The latter shall as I understand it happen when Iq = 0 and Id >0, but not in this case.
Does anybody have any ideas what the issue might be here?
Thanks,