

STEVAL-SPIN3202 Over Current Fault and Connection failed
Hello,
I am using a STEVAL-SPIN3202 to drive a small BLDC drone motor with a big motor speed constant KV = 7500rpm/V (MakerFire D1104 - 7500KV).
I used Motor Control Workbench 5.4.4, CubeMX 6.0.1 and CubeIDE 1.4.0 to build the code.
After some trouble with FLASH size (resolved with the compilation optimization settings), I was able to download the code on the board.
I'm now facing an other problem ;
I am able to connect to the device through Motor Control Workbench but each time I use the "Start Motor" button, some errors appear.
The first I had was Over Current Fault. I tried to change some settings but I always had the same fault.
After some changes on the settings and the jumpers (I can't remember exactly which), I'm getting a new error :
I can connect as usual but when I hit the "Start Motor" button, I can see the measured speed increase (the motor still doesn't move) and the error "Communication is closed, the board doesn't response correctly" appear.
Here is the detail of the motor :
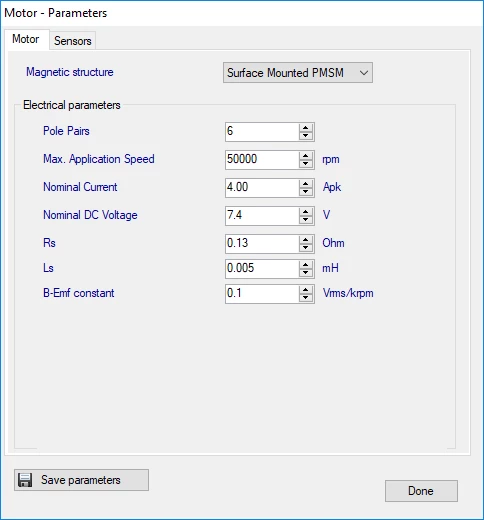
I even tried to make a fresh start by creating a new project but now a new problem arrived : RAM section excessed by 8 bytes. And unfortunately I don't know how to get rid of it.
I was wondering about 2 more things ;
- How can we chose between FOC or 6Step algorithm ? Is it only by changing the jumper on the board or is there something to do on Motor Control Workbench ?
- I have a warning saying "One shunt current sensing shall not be used with this motor (low inductance)"; STEVAL-SPIN3202 only has 1 shunt resistor, is it not possible to use 3 ?
Does anyone have an idea ?
So the 5 questions I have are about :
- Over Current Fault
- Communication is closed, the board doesn't response correctly
- RAM section exceded
- How to chose between FOC or 6step ? (Only with jumpers ?)
- One shunt resistor only for STEVAL-SPIN3202 ?
Sorry in advance for this big post and all the questions.
Thanks in advance.
Best regards,
Tristan