

Question
Countermeasure of Motor Profiler's Over-current at P-NUCLEO-IHM001
Posted on January 13, 2016 at 04:28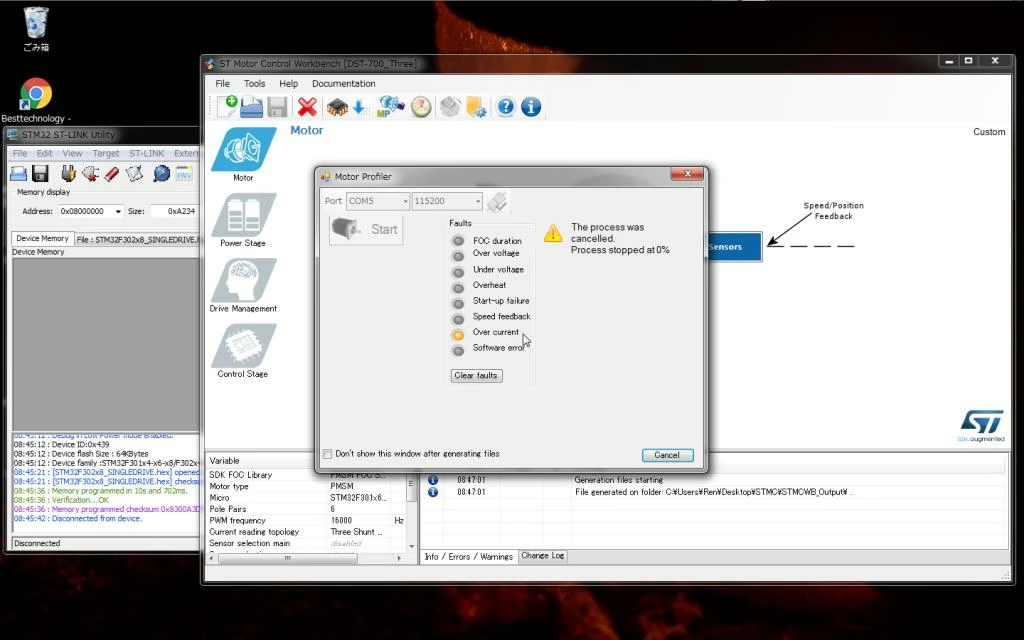 #p-nucleo-ihm001 #foc-sdk #dst700
Hi there.
I'm trying to learn FOC SDK using P-NUCLEO-IHM001.First test's firmware is ''STM32CubeExpansion_SPN7_V1.0.0\Projects\Multi\Examples\MotorControl\Binary\STM32F302R8-Nucleo\X-CUBE-SPN7.bin''.It worked(I judged it only just looking rotation of motor).Second test's firmware is output of project ''C:\Program Files\STMicroelectronics\FOC SDK\STM32 PMSM FOC LIBv4.2\Web\Project\MDK-ARM\UserProject\STM32F30x_UserProject.uvprojx''.(Using STMCWB outputs parameter.c/.h files, 3 shunt & 6 pole pair)It seems success about serial communication, However Over-Current faults occurs in a 1 seconds after push the [Start] button.I heard PWM sound would gradually get bigger.(Please check appended screenshot image...)Stabilized power supply indicated 0.05A, just before stop motor profiler.So I want to know 3 matters.1.How Motor Profiler judge current of first sequence. *STMCWB setting was default(nominal 2.1A).2.How can I tune(software/hardware) that range.3.Why X-CUBE-SPN7.bin was work.[Motor Spec]http://www.hobbyking.com/hobbyking/store/__42861__Turnigy_Aerodrive_DST_700_Brushless_Outrunner_motor_700kv.htmlPlease forgive me my lousy english.Best regards. #p-nucleo-ihm001 #foc-sdk #dst700