

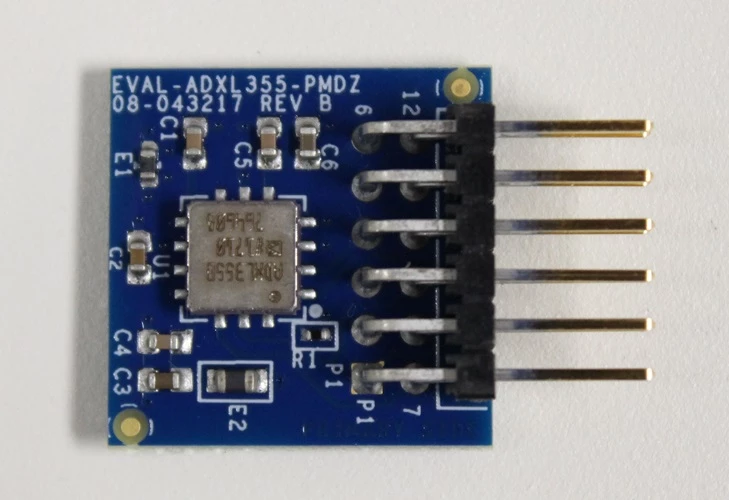
Hi everyone, I want to connect ADXL355 accelerometer sensor with stm32F407 mcu using I2C but, there is no any response from the sensor. Can anyone help me? Thanks...
ADXL355_Result ADXL355_Init(I2C_HandleTypeDef* I2Cx,ADXL355 * DataStruct, ADXL355_Device DeviceNumber, ADXL355_Accelerometer AccelerometerSensitivity)
{
uint8_t WHO_AM_I = (uint8_t)ADXL355_DEVID_AD ;
uint8_t temp;
I2C_HandleTypeDef* Handle = I2Cx;
/* Format I2C address */
DataStruct->Address = (uint8_t)DeviceNumber;
uint8_t address = DataStruct->Address;
/* Check if device is connected */
if(HAL_I2C_IsDeviceReady(Handle,address,2,5)!=HAL_OK)
{
return ADXL355_Result_Error;
}
if(HAL_I2C_Mem_Read(Handle, address, WHO_AM_I, 1, &temp, 1, 1000) != HAL_OK)
{
return ADXL355_Result_Error;
}
/* Checking */
while(temp != ADXL355_ID)
{
/* Return error */
return ADXL355_Result_DeviceInvalid;
}
//------------------
/* POWER_CTL */
//------------------
/* Set POWER_CTL register */
if(ADXL355_POWERCTL(I2Cx , DataStruct) != ADXL355_Result_Ok)
{
return ADXL355_Result_Error;
}
//------------------
/* Config accelerometer */
ADXL355_SetAccelerometer(I2Cx,DataStruct, AccelerometerSensitivity);
/* Return OK */
return ADXL355_Result_Ok;
}
ADXL355_Result ADXL355_SetAccelerometer(I2C_HandleTypeDef* I2Cx,ADXL355* DataStruct, ADXL355_Accelerometer AccelerometerSensitivity)
{
uint8_t temp;
I2C_HandleTypeDef* Handle = I2Cx;
uint8_t address = DataStruct->Address;
uint8_t regAdd =(uint8_t )ADXL355_Range;
/* Config accelerometer */
while(HAL_I2C_Master_Transmit(Handle, (uint16_t)address,®Add, 1, 1000) != HAL_OK);
/*{
return SD_MPU6050_Result_Error;
}*/
while(HAL_I2C_Master_Receive(Handle, (uint16_t)address, &temp, 1, 1000) != HAL_OK);
/*{
return SD_MPU6050_Result_Error;
}*/
temp = (temp & 0xFC) | (uint8_t)AccelerometerSensitivity ;
while(HAL_I2C_Master_Transmit(Handle, (uint16_t)address,&temp, 1, 1000) != HAL_OK);
/*{
return SD_MPU6050_Result_Error;
}*/
/* Set sensitivities for multiplying gyro and accelerometer data */
switch (AccelerometerSensitivity) {
case ADXL355_Accelerometer_2G:
DataStruct->Acce_Mult = (float)1 / ADXL355_ACCE_SENS_2;
break;
case ADXL355_Accelerometer_4G:
DataStruct->Acce_Mult = (float)1 / ADXL355_ACCE_SENS_4;
break;
case ADXL355_Accelerometer_8G:
DataStruct->Acce_Mult = (float)1 / ADXL355_ACCE_SENS_8;
break;
default:
break;
}
/* Return OK */
return ADXL355_Result_Ok;
}
ADXL355_Result ADXL355_POWERCTL(I2C_HandleTypeDef* I2Cx, ADXL355* DataStruct)
{
uint8_t temp;
I2C_HandleTypeDef* Handle = I2Cx;
uint8_t address = DataStruct->Address;
uint8_t regAdd =(uint8_t )ADXL355_POWER_CTL;
/* Config accelerometer */
while(HAL_I2C_Master_Transmit(Handle, (uint16_t)address,®Add, 1, 1000) != HAL_OK)
{
return ADXL355_Result_Error;
}
while(HAL_I2C_Master_Receive(Handle, (uint16_t)address, &temp, 1, 1000) != HAL_OK)
{
return ADXL355_Result_Error;
}
temp = temp & 0xFE ; // Set measurement bit in POWER_CTL register
while(HAL_I2C_Master_Transmit(Handle, (uint16_t)address,&temp, 1, 1000) != HAL_OK)
{
return ADXL355_Result_Error;
}
return ADXL355_Result_Ok;
}
ADXL355_Result ADXL355_ReadAccelerometer(I2C_HandleTypeDef* I2Cx,ADXL355* DataStruct)
{
uint32_t X = 0, Y = 0 , Z = 0;
uint8_t data[9];
uint8_t reg = ADXL355_XDATA3 ;
I2C_HandleTypeDef* Handle = I2Cx ;
uint8_t address = DataStruct->Address ;
/* Read accelerometer data */
//while(HAL_I2C_Master_Transmit(Handle, (uint16_t)address, ®, 1, 1000) != HAL_OK) ;
while(HAL_I2C_Mem_Read(Handle, address, reg, 1, data , 6, 1000) != HAL_OK) ;
for(int t=0;t<3;t++)
{
X<<=8;
X+=data[t];
}
for(int t=3;t<6;t++)
{
Y<<=8;
Y+=data[t];
}
for(int t=6;t<9;t++)
{
Z<<=8;
Z+=data[t];
}
DataStruct->Accelerometer_X = ADXL355_Acceleration_Data_Conversion(X);
DataStruct->Accelerometer_Y = ADXL355_Acceleration_Data_Conversion(Y);
DataStruct->Accelerometer_Z = ADXL355_Acceleration_Data_Conversion(Z);
ADXL_AX = (float)DataStruct->Accelerometer_X*DataStruct->Acce_Mult;
ADXL_AY = (float)DataStruct->Accelerometer_Y*DataStruct->Acce_Mult;
ADXL_AZ = (float)DataStruct->Accelerometer_Z*DataStruct->Acce_Mult;
/* Return OK */
return ADXL355_Result_Ok;
}