
Associate
April 2, 2025
Question

VL53L0X API Library - division by Zero fault in VL53L0X_calc_timeout_mclks

  • April 2, 2025
  • 2 replies
  • 1670 views

Hello ST Team!

In one of my new projects i use the VL53L0X TOF Sensor to measure simple distances.

The mcu i use is the STM32F103.

To get values from the sensor i use the ST API Library. It's kind of s special version since i use the modified one which is working with the Cube MX Hal.

This is the repository i cloned and pointing to the master branch:

STM32CubeL4/Projects/B-L475E-IOT01A/Applications/Proximity at master · STMicroelectronics/STM32CubeL4 · GitHub

As this project is for the L4 i just replaced the hal include from 

#include "stm32l4xx_hal.h" to  #include "stm32f1xx_hal.h"

in the vl53l0x_platform.h file. 

1. The INIT VL53L0X_PROXIMITY_Init() finishes without errors

2. The problem occurs when i do  VL53L0X_PROXIMITY_GetDistance() 

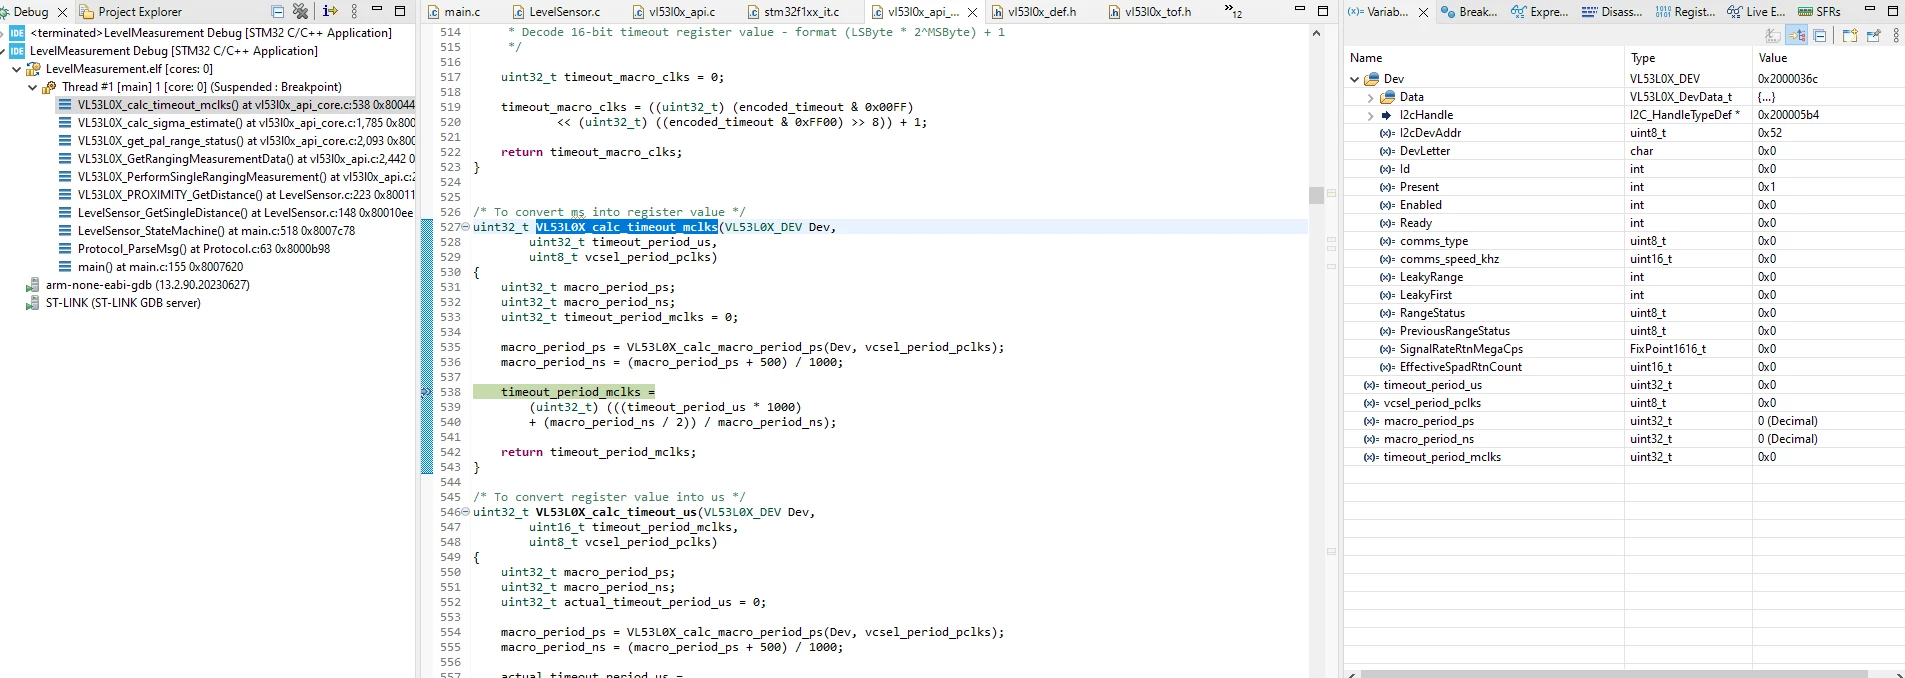
Within the function VL53L0X_calc_timeout_mclks() the division by zero fault occurs and i don't know exactly why since the range measurement is already done correctly.

Following depicts the callstack before the divsion happens.
LukasA93_0-1743615159535.png

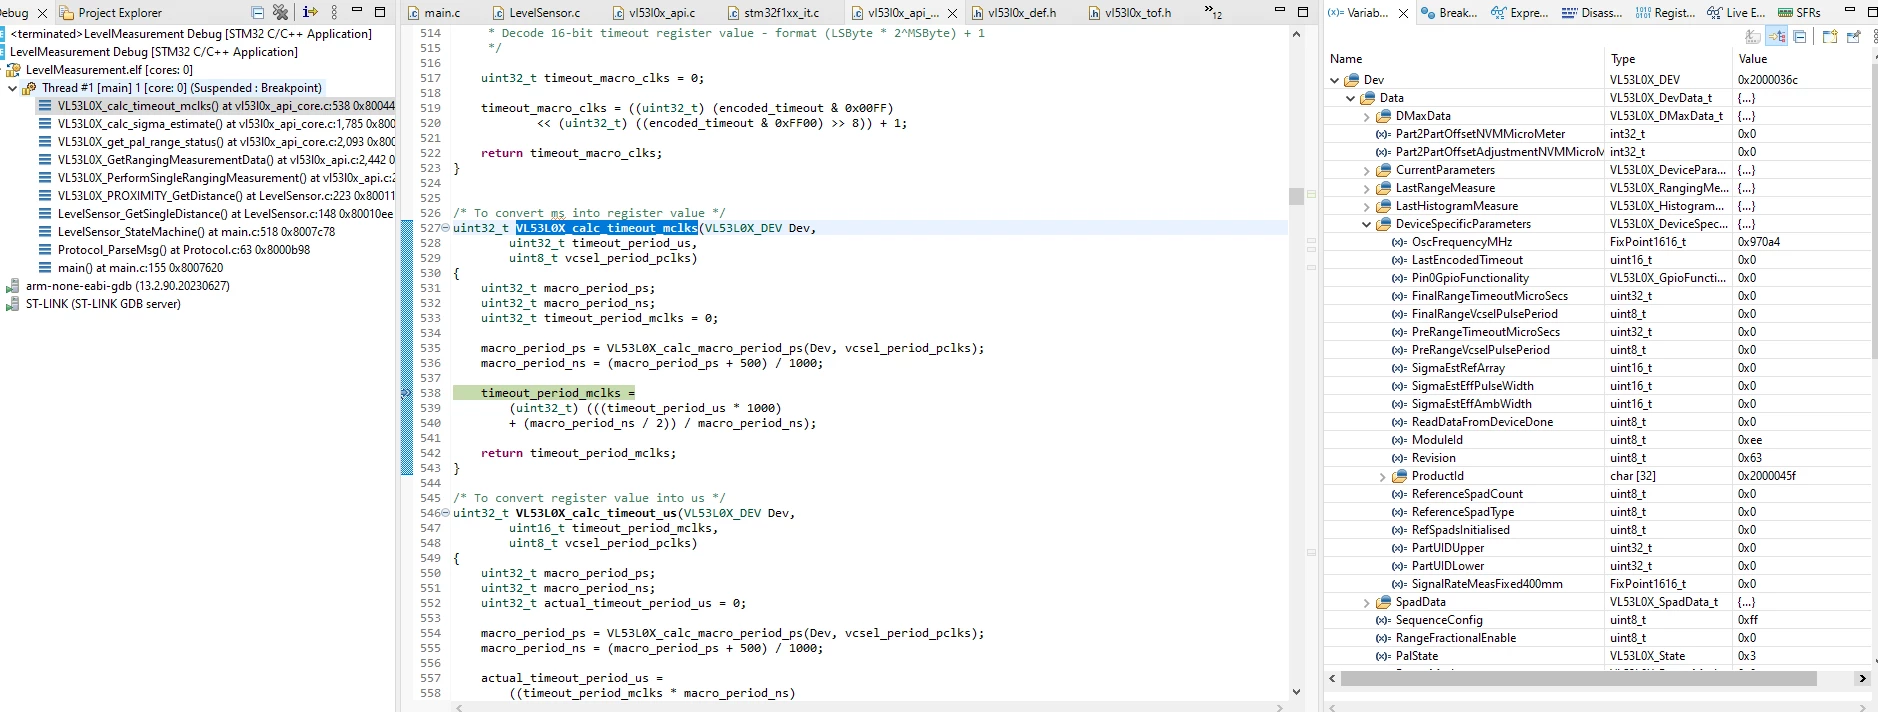
Additionally the "DeviceSpecificParameters"
LukasA93_1-1743615251795.png

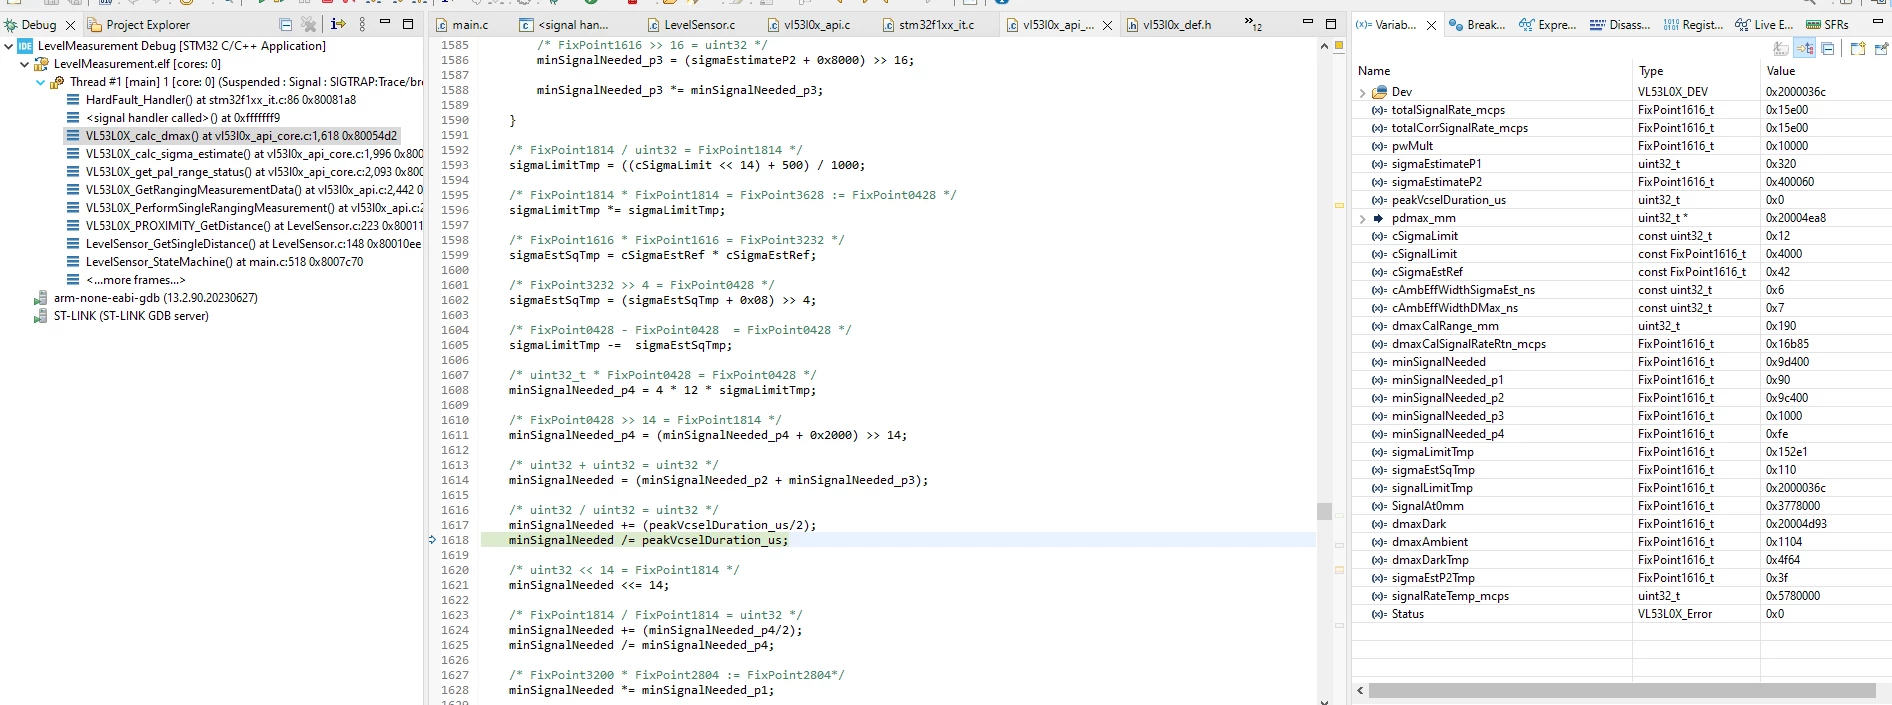
If I work around this the next division by zero is following immediatly.
LukasA93_2-1743615848780.png


Can you give me some hints why the zero division is happening? 
Do i have to set some parameters as mentioned here? : VL53L0X Divide by Zero error in API - STMicroelectronics Community

Problem is that i do not have the VL53L0_i2c_platfform.c platform files.


Thank you in advance!
Regards, Lukas

This topic has been closed for replies.

2 replies

John E KVAM
ST Employee
April 2, 2025

I doubt yours is the same error. His was a porting error and you are using an STM32, so the timing functions should work. 

I will grant you that one really should follow the advice in that issue though. 

"...by checking for a zero value (and setting to 1) before doing the (divide)."

But yours is the first mention I've heard of in 4 years, so I'm going to guess it's your configuration.

Although I really can't point to where you might have gone wrong. 

Could you post all your sensor initialization calls?

I'm betting there is something amiss in those.

- john 

If this or any post solves your issue, please mark them as 'Accept as Solution' It really helps. And if you notice anything wrong do not hesitate to 'Report Inappropriate Content'. Someone will review it.
LukasA93Author
Associate
April 2, 2025

Thank you for your fast reply!


1. VL53L0X_PROXIMITY_Init();

2. VL53L0X_PROXIMITY_GetDistance();

This is the Init routine:

/**
 * @brief VL53L0X proximity sensor Initialization.
 */
 static void VL53L0X_PROXIMITY_Init(void)
 {
 uint16_t vl53l0x_id = 0; 
 VL53L0X_DeviceInfo_t VL53L0X_DeviceInfo;
 
 /* Initialize IO interface */
 //SENSOR_IO_Init(); --> I2C is already initialized in main.c
 VL53L0X_PROXIMITY_MspInit();
 
 memset(&VL53L0X_DeviceInfo, 0, sizeof(VL53L0X_DeviceInfo_t));
 
 if (VL53L0X_ERROR_NONE == VL53L0X_GetDeviceInfo(&Vl53Instance, &VL53L0X_DeviceInfo))
 { 
	 if (VL53L0X_ERROR_NONE == VL53L0X_RdWord(&Vl53Instance, VL53L0X_REG_IDENTIFICATION_MODEL_ID, (uint16_t *) &vl53l0x_id))
	 {
	 if (vl53l0x_id == VL53L0X_ID)
	 {
		 if (VL53L0X_ERROR_NONE == VL53L0X_DataInit(&Vl53Instance))
		 {
			Vl53Instance.Present = 1;
		 SetupSingleShot(Vl53Instance);
		 }
		 else
		 { 
		 printf("VL53L0X Time of Flight Failed to send its ID!\n");
		 }
	 }
	 }
	 else
	 {
	 printf("VL53L0X Time of Flight Failed to Initialize!\n");
	 }
 }
 else
 {
	 printf("VL53L0X Time of Flight Failed to get infos!\n");
 } 
 }

Additional Msp Init function and the GetDistance function

/**
 * @brief VL53L0X proximity sensor Msp Initialization.
 */
 static void VL53L0X_PROXIMITY_MspInit(void)
 {
 // done at hal init
 //GPIO_InitTypeDef GPIO_InitStruct;
 //
 ///*Configure GPIO pin : VL53L0X_XSHUT_Pin */
 //GPIO_InitStruct.Pin = VL53L0X_XSHUT_Pin;
 //GPIO_InitStruct.Mode = GPIO_MODE_OUTPUT_PP;
 //GPIO_InitStruct.Pull = GPIO_PULLUP;
 //GPIO_InitStruct.Speed = GPIO_SPEED_FREQ_HIGH;
 //HAL_GPIO_Init(VL53L0X_XSHUT_GPIO_Port, &GPIO_InitStruct);
 
 HAL_GPIO_WritePin(VL53L0X_XSHUT_GPIO_Port, VL53L0X_XSHUT_Pin, GPIO_PIN_SET);
 
 HAL_Delay(1000); 
 }

 /**
 * @brief Get distance from VL53L0X proximity sensor.
 * @retval Distance in mm
 */
static uint16_t VL53L0X_PROXIMITY_GetDistance(void)
{
 VL53L0X_RangingMeasurementData_t RangingMeasurementData;
 // TODO - Error handling
 VL53L0X_PerformSingleRangingMeasurement(&Vl53Instance, &RangingMeasurementData);
 
 return RangingMeasurementData.RangeMilliMeter; 
}

 Additionally attached the vl53l0x_tof.c file where the SetupSingleShot function is defined.

Basically it is all the same as in the nucleo example mentioned in the first post.


Regards, Lukas